
When you engage an automation system integrator malaysia for a turnkey project, most delays and quality disputes come from unclear requirements, vague acceptance criteria, and weak handover—not “bad programming” alone. This tutorial explains four execution pillars that make commissioning predictable: URS, FAT/SAT, cycle time validation, and handover documentation.
The objective is to make expectations measurable, testable, and traceable from day one. Whether your system includes cobots, industrial robots, conveyors, machine vision and inspection, robotic soldering, or an AMR machine for internal logistics, the same acceptance structure applies.
Step 1: Write a URS that an integrator can build and test
A User Requirements Specification (URS) is a contract-grade definition of what the system must do, under what conditions, and how you will verify it. If the URS is vague, FAT and SAT become subjective—leading to arguments at sign-off.
1.1 Start with scope boundaries (what is included vs excluded)
Define the system boundary early and in writing—what the integrator delivers versus what is by others. Clarify:
- Mechanical scope: fixtures, tooling, guarding, conveyors, pallets, reject bins.
- Controls scope: PLC/safety PLC or relay, HMI language, network interfaces.
- Process scope: soldering parameters, torque/dispense tolerances, inspection criteria.
- Utilities: power, air, vacuum, extraction, ESD, compressed air quality.
1.2 Convert “needs” into measurable acceptance criteria
Write requirements so each one can be verified during FAT/SAT. Examples:
- Cycle time: “Average cycle time ≤ X seconds at Y% line efficiency, measured over N consecutive good parts.”
- Quality: “Vision inspection detects missing component and polarity errors to defined thresholds; false reject rate ≤ agreed limit during test run.”
- Traceability: “Log part ID (barcode/QR), timestamp, station result, reject reason; export CSV to a network share.”
- Safety: “Cell complies with a documented risk assessment; safety functions tested with recorded results.”
Avoid terms like “high speed”, “user friendly”, or “stable” unless you define how to measure them.
1.3 Include realistic product and process data
Design quality depends on input quality. Provide drawings/tolerances, photos, materials, surface conditions, and allowed variation. For auto soldering or a robotic soldering system, include PCB variants, flux requirements, tip access constraints, and internal inspection standards.
If multiple SKUs are involved, define changeover expectations: change parts, recipe selection, vision re-teach, and target changeover time.
1.4 Build a traceability backbone: URS → FDS → test cases
Ask for an requirements traceability matrix (RTM) that links:
- URS: what the user needs
- FDS/SDS: how the design meets those needs
- FAT/SAT test cases: how each requirement is verified
This reduces “we thought you meant…” disputes and controls change impact.
Step 2: Plan FAT and SAT so acceptance is objective
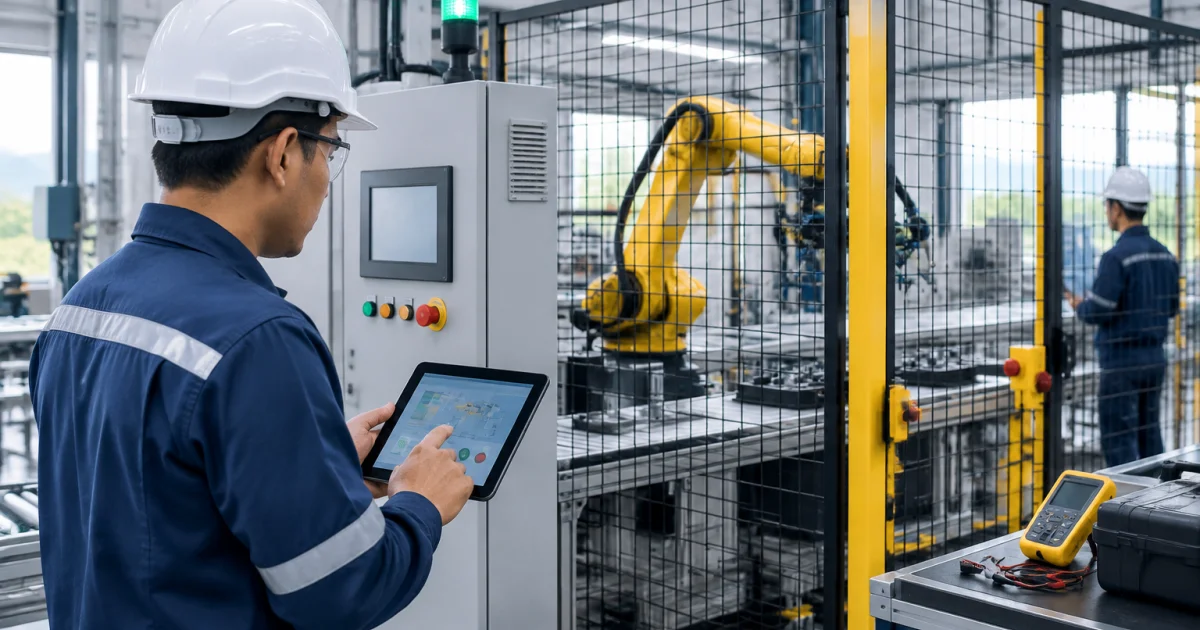
Factory Acceptance Test (FAT) reduces build risk before shipment; Site Acceptance Test (SAT) proves performance in your real factory with your utilities, operators, and line interfaces.
2.1 Create a FAT checklist with clear entry conditions
Define what must be complete before FAT starts. Typical entry criteria:
- Mechanical build complete (guarding, end-effector, sensors installed).
- Electrical wiring complete/labeled; drawings updated to “as-built draft”.
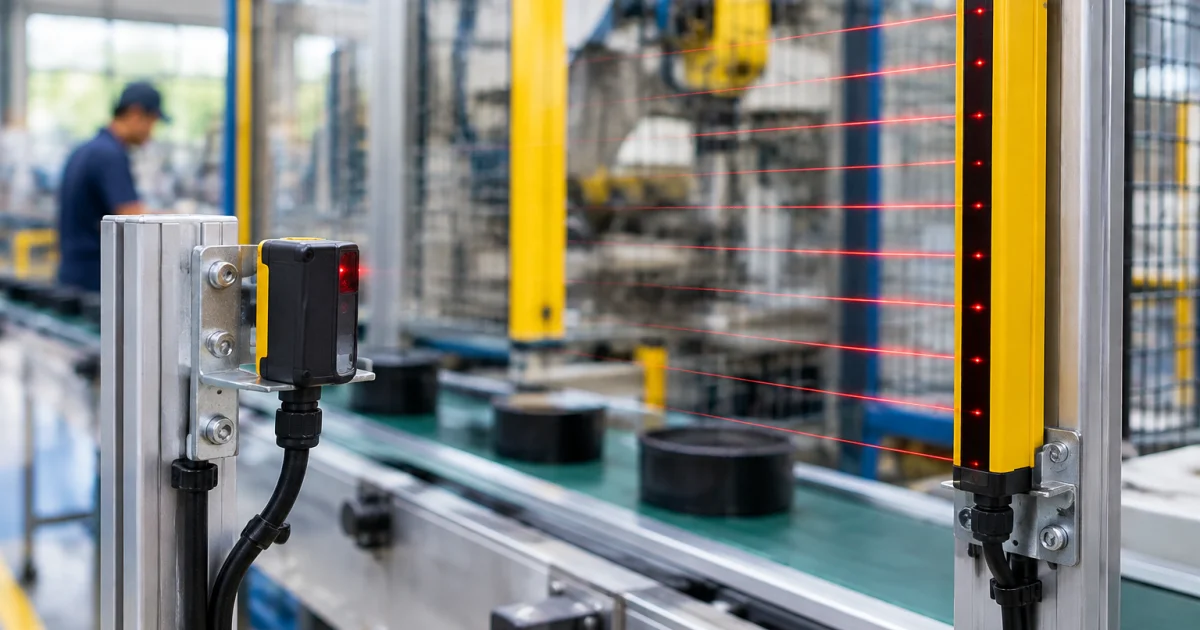
- Safety devices installed (scanners/light curtains/interlocks/E-stops).
- PLC/HMI baseline software loaded; versions documented.
- Spare parts list and recommended consumables drafted.
For machine vision & inspection systems, ensure lighting is installed, camera mounts are fixed, and a representative golden sample set is available.
2.2 Define the FAT test structure (functional, safety, quality, and data)
A practical FAT pack typically includes:
- Functional tests: auto/manual modes, interlocks, alarms, recipes, recovery steps.
- Safety tests: E-stops, interlocks, scanner zones, safety I/O checks, reset logic.
- Process tests: soldering path, dispensing/torque results, pick-and-place accuracy, machine tending sequence.
- Inspection tests: known-good vs known-bad samples; thresholds recorded.
- Data tests: traceability fields, exports, backup/restore procedure.
Require controlled test records (results, observations, sign-offs) plus a punch list. If something fails, classify it as “must-fix before shipment” or “close in SAT”, and document the decision.
2.3 Prepare SAT to validate the real factory constraints
SAT often reveals issues FAT cannot: line balancing, operator handling, air quality, EMI noise, floor conditions, and network access. A strong SAT plan includes:
- Site readiness: utilities, clearance, network ports, staging, EHS approvals.
- Integration checks: upstream/downstream signals, conveyor handshakes, MES/ERP connectivity (if applicable).
- Workflow validation: loading/unloading ergonomics, replenishment, reject handling, tool access.
- Run-at-rate trial: sustained production run using agreed measurement rules.
For internal logistics using an AMR machine, verify routes, docking accuracy, traffic rules, and obstacle handling in real aisles.
Step 3: Validate cycle time properly (and avoid misleading numbers)
Cycle time conflicts happen because teams measure different things (robot motion only vs. full cycle including load/unload, barcode read, vision retries). Agree one method and document it.
3.1 Define the cycle time model in writing
Include these definitions in the URS or test plan:
- Start/stop points: e.g., start when cycle begins with part present; stop when part is in OK bin and cell is ready for the next part.
- Part type/condition: which SKU and whether parts are pre-aligned or random.
- Included events: vision capture, barcode reading, solder dwell, tip clean cycle, conveyor indexing.
- Excluded events: planned maintenance, replenishment, shift change (if excluded, state it).
3.2 Use a run-at-rate method that reflects production reality
A practical validation procedure:
- Stabilize the cell: warm-up, home axes, confirm sensor baselines.
- Run N consecutive cycles: choose N to smooth variation and agree it upfront.
- Log automatically: PLC/HMI timestamps are more reliable than stopwatch timing.
- Separate normal vs exception cycles: record reasons for retries, rejects, or pauses.
- Report average and worst-case: average for capacity; worst-case for line-balance risk.
For robotic vision inspection, define what happens on uncertain results (re-capture, adjust lighting, or request operator confirmation) because these rules directly affect throughput.
3.3 Verify throughput, not just single-station speed
Systems can meet station cycle time yet miss line targets due to buffering and handshakes. During SAT, validate:
- Conveyor accumulation logic and sensor placement.
- Reject flow capacity (bins/trays don’t overflow and stop the line).
- Replenishment intervals (tape, trays, solder wire, flux, labels).
- Recoverability after faults (time to resume after E-stop, jams, vision fails).
Capture a short capacity note: sustainable throughput, top bottlenecks, and practical improvements (e.g., gripper changes, lighting updates, feeder orientation, or PLC sequence tuning).
Step 4: Handover documentation that protects uptime after commissioning
A system is truly “done” when your team can operate, maintain, and troubleshoot it without guessing. A clear handover package reduces downtime and dependence on tribal knowledge.
4.1 Define the handover package before the build starts
Agree deliverables early so they are planned and budgeted. A complete handover pack typically includes:
- As-built drawings: electrical schematics, panel layout, I/O list, pneumatics, network topology.
- Software deliverables: PLC source/project, HMI project, robot programs, vision recipes, backups, version list.
- Operation manuals: start/stop, modes, changeover, fault recovery.
- Maintenance plan: lubrication points, inspection intervals, wear parts, calibration routines.
- Spare parts list: critical sensors, grippers, belts, fuses/relays, camera/lighting components, vendor part numbers.
- Training records: attendance and topics covered (plus competency sign-off if used internally).
4.2 Include a “troubleshooting map” for faster response
Request a troubleshooting guide aligned to HMI alarms, including:
- Plain-language alarm description.
- Most likely causes.
- Safe checks to perform first.
- Clear recovery steps and escalation guidance.
For soldering systems, add process-focused checks (tip wear indicators, solder feed problems, temperature stability, and post-intervention solder quality verification).
4.3 Close the loop with punch-list governance
Every FAT/SAT produces open items; governance prevents them becoming long-term downtime:
- Classify items: safety-critical, production-critical, cosmetic, documentation-only.
- Assign owners and due dates.
- Define closure evidence (photo, updated drawing, test record).
- Control changes: update the RTM and rerun impacted tests when behavior changes.
Step 5: How to evaluate and work with an integrator during commissioning
Commissioning works best as a managed collaboration with clear communication, responsibilities, and escalation paths.
5.1 Use a single acceptance dossier
Maintain one shared dossier containing the URS, RTM, FAT and SAT reports, cycle time validation report, safety verification records, and the final handover index. Ensure both parties work from the same revision set.
5.2 Make responsibilities explicit (RACI-style)
Define who provides samples, site readiness/utilities, network access, rigging/forklift support, EHS approvals, and operator scheduling. Many delays happen when ownership is assumed rather than assigned.
5.3 Confirm the integrator’s technical breadth matches your cell needs
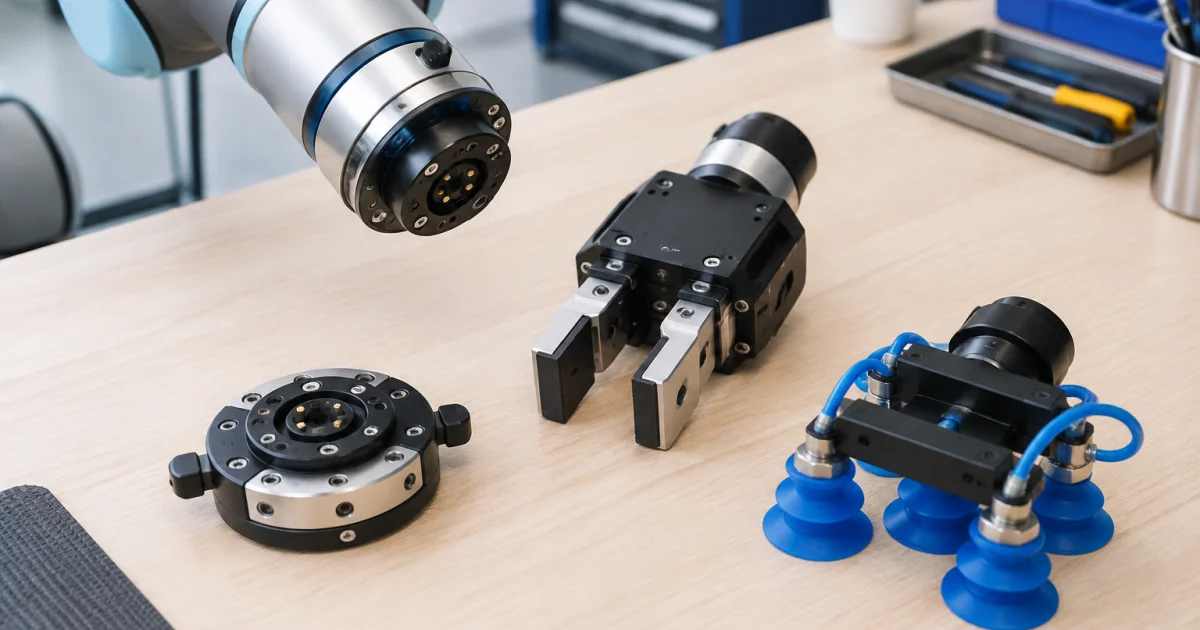
A capable machine integrator in Malaysia should cover robotics, sensors, safety, controls, and inspection. If you require vision inspection machines, barcode traceability, or force/torque sensing end-effectors, confirm these competencies upfront and review the proposed architecture in the FDS.
Conclusion: Make acceptance measurable, and commissioning becomes predictable
A URS written in measurable terms, evidence-based FAT/SAT, cycle time validation with shared definitions, and a complete handover package protect budget, timeline, and long-term maintainability. You don’t need excessive paperwork—you need the right documents that connect requirements to tests and uptime.
If you’re preparing to engage an automation partner for robots, machine vision, robotic soldering, or internal logistics automation, use this tutorial as a commissioning checklist to compare proposals objectively and accept systems with fewer surprises.
Useful next reads
- Robotic soldering machine overview
- Welding robotic arm project example
- Basler camera accessories for machine vision applications
Frequently Asked Questions
What is the difference between URS and FDS in an automation project?
URS (User Requirements Specification) states what the user needs in measurable terms (outputs, constraints, acceptance criteria). FDS (Functional Design Specification) explains how the system will meet those needs (sequence logic, interfaces, alarms, recipes, safety functions). A good project links URS items to FDS sections and then to FAT/SAT test cases via a traceability matrix.
What should be included in a FAT for a robot cell with vision inspection?
A practical FAT should cover functional sequences (auto/manual, interlocks, alarms), safety device verification (E-stops, doors, scanners, reset logic), vision setup checks (lighting, camera mounting stability, golden samples, pass/fail thresholds), and data/traceability tests (barcode/QR reading, result logging, exports). The FAT report should include recorded results, issues found, and a punch list with owners and closure criteria.
How do you measure and validate cycle time fairly during SAT?
First, define the start and end points and what is included (vision capture, barcode read, soldering dwell, indexing) versus excluded (shift change, replenishment). Then run a sustained trial with an agreed number of consecutive cycles, ideally using PLC/HMI timestamps rather than a stopwatch. Report average and worst-case cycle time, and document exceptions (retries, rejects, micro-stops) with reasons so both sides interpret the results the same way.
What handover documents should I request from an automation system integrator?
Request an indexed handover pack that includes as-built electrical and pneumatic drawings, I/O list, network topology, PLC/HMI/robot/vision source files and backups with version list, operation and maintenance manuals, a spare parts list with part numbers, calibration routines, and training records. Also ask for an alarm-based troubleshooting guide that matches the HMI messages and gives safe recovery steps.
When should issues be fixed at FAT versus carried to SAT?
Fix safety-critical and shipment-risk items before delivery whenever possible (guarding, interlocks, safety logic, major mechanical faults). Items that depend on site conditions—like network connectivity, line balancing with upstream conveyors, or final vision thresholds based on real factory lighting—may be closed during SAT, but they must be clearly listed in a punch list with owners, due dates, and acceptance evidence required for closure.
Need a turnkey commissioning plan for your automation project?
Chin Tech supports manufacturers with end-to-end automation system integration—from URS alignment and test planning to FAT/SAT execution, cycle time validation, and complete handover documentation. If you are scoping a new robot cell, machine vision inspection, robotic soldering, or internal logistics automation, we can help you define measurable acceptance criteria and commission with confidence.